
DS FlexRC™ SmartCell™ Modular Robotic Surface Finishing Platform
DS FlexRC™ Robotic Surface Finishing Tools
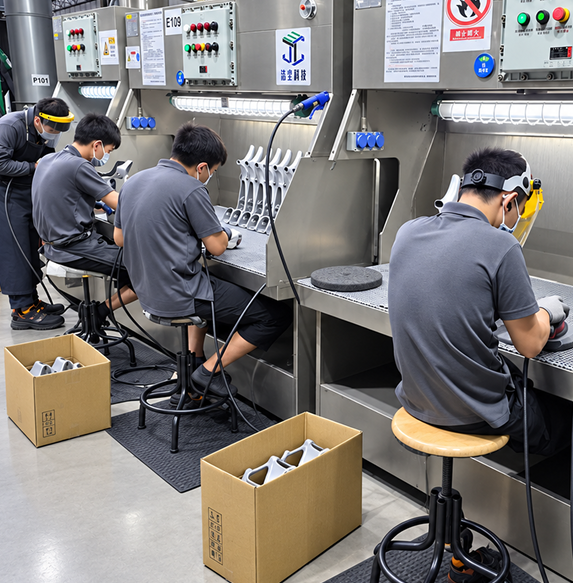
Components after casting, welding, machining, and forming often still require processes such as blasting, deburring, grinding, weld finishing, polishing, and surface finishing.
These processes depend heavily on contact force, toolpath, tool condition, material properties, and operator experience. Manual processing is easily affected by workpiece variation and operator skill, making it difficult to maintain consistent results over time in high-volume or high-quality production.
By integrating robotics, compliant force control, dedicated process tools, and process know-how, DS transforms surface finishing operations that traditionally rely heavily on manual expertise into controllable, repeatable, and scalable automated processes.
01
Surface finishing processes such as grinding, deburring, blasting, and polishing rely heavily on operator experience. Skilled workers take time to develop, while process results can vary between operators. Robotics and standardized process parameters help reduce dependence on skilled labor, stabilize production cycle times and processing quality, and improve repeatability and consistency in mass production.
02
Workpiece tolerances, surface geometry, material properties, and tool wear directly affect material removal and final surface quality. Compliant force control, toolpath management, and process parameter control help maintain stable contact force and processing conditions, reducing over-grinding, under-grinding, and surface irregularities while improving surface quality consistency.
03
Traditional blasting, grinding, and polishing processes often involve dust, noise, vibration, physically demanding work, and highly repetitive tasks. Extended exposure can create challenges for the working environment and occupational safety. Robotics reduces direct operator exposure to high-load and higher-risk processes while improving workplace conditions and operational safety.
04
Workpieces with different materials, sizes, and geometries require different tools, contact forces, toolpaths, and surface quality specifications. Modular equipment, quick tool change, and offline programming enable rapid process reconfiguration, supporting both high-mix production and mass production across applications ranging from large castings and welded structures to CNC precision parts, carbon-fiber components, and jewelry parts.
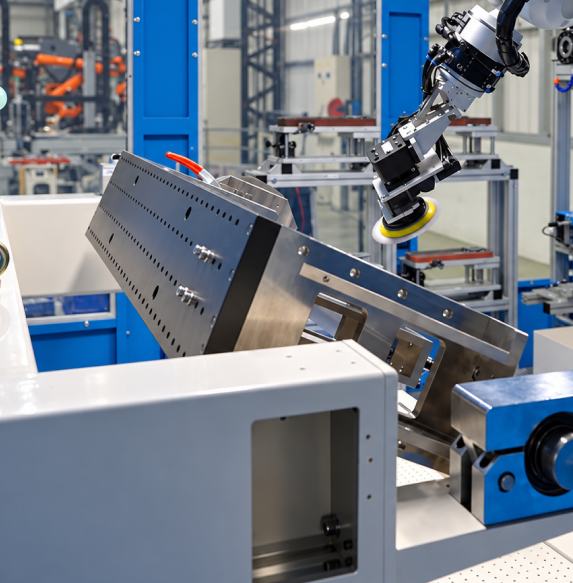
DS robotic surface finishing solutions cover blasting, deburring, grinding, weld finishing, polishing, and precision surface finishing. Applications include castings, welded structures, CNC-machined parts, tubing, and composite materials, and extend to AI servers, LEO satellites, semiconductor equipment, jewelry, and precision decorative components.
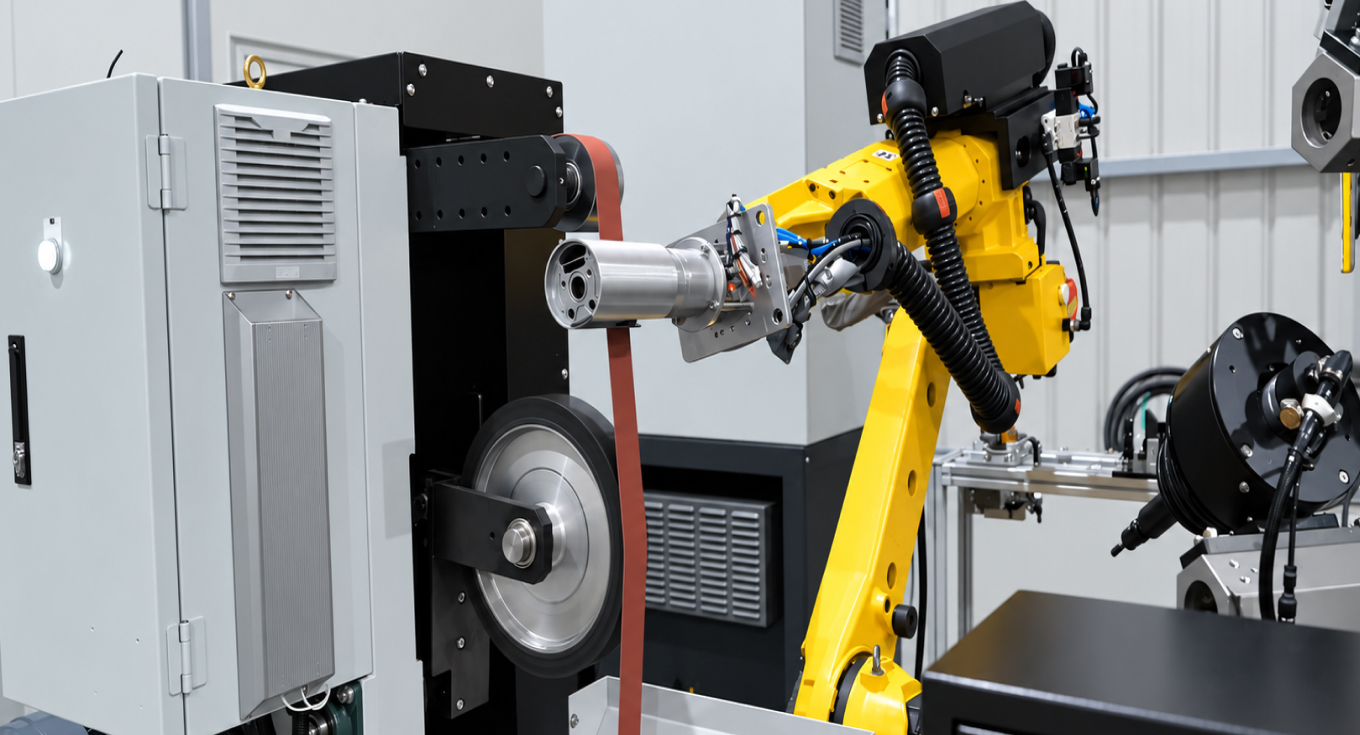
Depending on the workpiece material, size, geometry, and surface quality requirements, the system can integrate robotic blasting equipment, active/passive compliant tools, belt grinding equipment, flap wheels, and polishing tools. It supports processes ranging from surface cleaning and high-material-removal grinding to complex-surface finishing and precision polishing for high cosmetic quality.
Through FlexRC™ compliant force control, standardized equipment, and DS process know-how, surface finishing operations that traditionally rely heavily on manual expertise are transformed into controllable, scalable, traceable, and continuously optimizable automation capabilities.
After casting, welding, forming, and machining, components often still require blasting, deburring, grinding, weld finishing, polishing, and surface finishing. These processes can be affected by workpiece tolerances, surface geometry, material properties, tool wear, and operator experience, creating challenges in quality consistency, production efficiency, and operational safety.
With more than 11 years of experience in robotic surface finishing technology and process applications, DS integrates FlexRC™ compliant force control, dedicated process tools, modular equipment, Robotmaster® offline programming, automatic robot TCP calibration, and Turnkey system integration. Solutions can be configured according to material, workpiece size, geometry, and surface quality requirements, covering process testing, tool selection, path planning, and complete system implementation.
DS uses standardized and modular architectures to simplify the implementation of surface finishing automation, providing equipment configurations tailored to different workpieces and process requirements.
Architecture
Robot-holds-tool dual-station modular workstation
Suitable Workpieces
Medium to large workpieces, complex surfaces, multi-area
Applicable Processes
Grinding, deburring, and surface finishing.
Architecture
Robot-holds-workpiece modular workstation
Suitable Workpieces
Small to medium-sized workpieces and multi-process applications
Applicable Processes
Grinding, deburring, polishing, and precision surface finishing.
Architecture
Collaborative robot-holds-tool surface finishing workstation designed for human-robot collaboration and flexible deployment
Suitable Workpieces
Medium to large workpieces, localized processing
Applicable Processes
Small-batch production, and high-mix manufacturing.
In addition to standardized equipment, DS can design customized Turnkey surface finishing systems based on production capacity, cycle time, workpiece size, and process requirements.
Depending on the process, the system can integrate robotic blasting equipment, active/passive compliant tools, belt grinding equipment, flap wheels, and polishing tools for metals, plastics, ceramics, carbon-fiber composites, and other engineering materials.
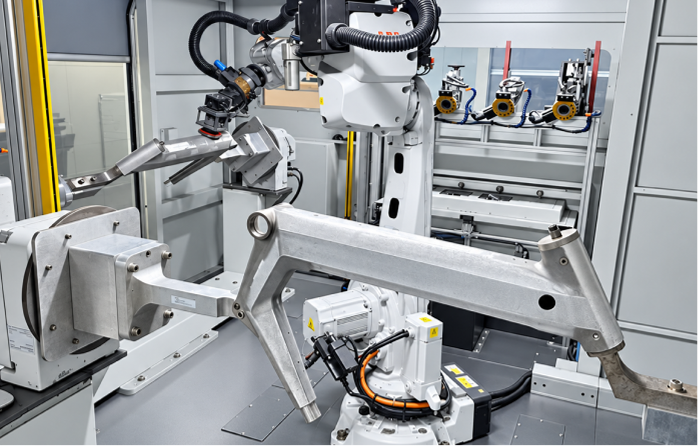
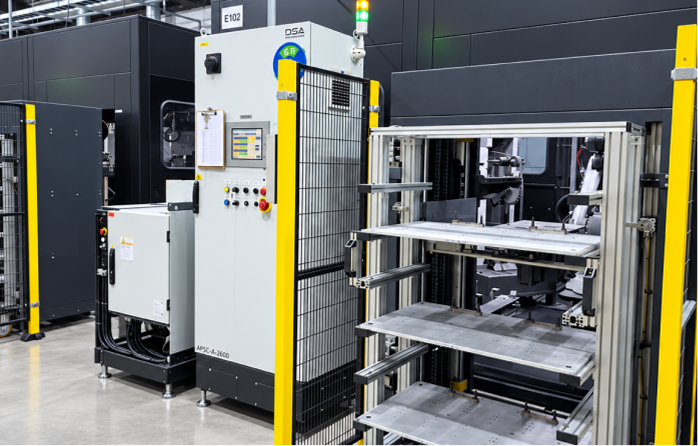
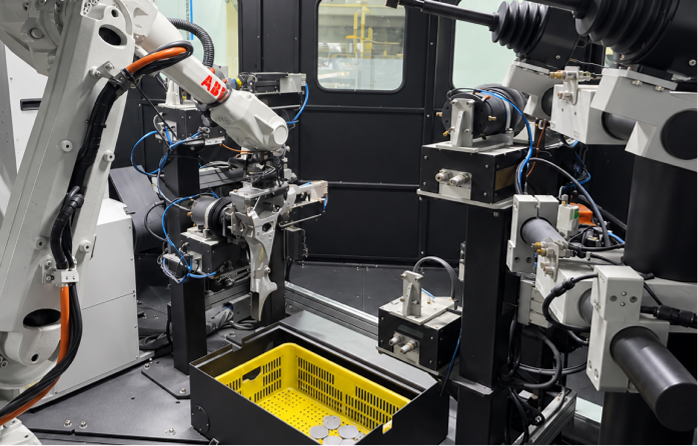
Select the most suitable finishing method based on production volume, workpiece complexity, quality requirements, and process flexibility.
| Item | Robotic Surface Finishing | Manual Surface Finishing |
| Production Efficiency | Suitable for extended continuous operation and medium- to high-volume production, with stable cycle times. | Suitable for low-volume production, prototyping, and flexible operations, with output more dependent on workforce availability. |
| Process Quality & Consistency | Compliant force control, toolpath management, and process parameter control improve repeatability and surface quality consistency. | Allows real-time adjustment to workpiece conditions, but results are more affected by operator experience and operating differences. |
| Process Standardization | Toolpaths, tools, contact force, and process parameters can be standardized and reused. | Highly flexible, but more dependent on operator experience and work procedures. |
| Complex Geometry Capability | With TCP calibration, Robotmaster® offline programming, and compliant force control, the system can handle a wide range of regular geometries and complex surfaces. | Highly flexible for tight corners, special geometries, and localized finishing. |
| High-Mix / Low-Volume Flexibility | Modular equipment, program switching, and tool changes support high-mix production, although initial process setup is required. | Well suited to low-volume production, prototyping, and frequently changing workpieces. |
| Labor Requirements | Reduces labor requirements for repetitive, physically demanding, and skill-intensive finishing operations, allowing operators to focus on loading/unloading, quality inspection, and final touch-up. | Relies primarily on skilled operators, with capacity and quality more affected by workforce availability and experience. |
| Working Environment & Safety | Reduces direct operator exposure to dust, noise, vibration, and highly repetitive work. | Operators perform the process directly and require appropriate dust collection, protective equipment, and occupational safety measures. |
| Process Flexibility | Suitable for standardized and repeatable processes, with flexibility added through changeovers, tool changes, and reprogramming. | Provides greater immediate flexibility for special workpieces, localized finishing, and last-minute changes. |
| Equipment & Process Management | Equipment status, process parameters, and production information can be recorded and integrated with smart manufacturing systems. | Primarily relies on manual records and on-site management. |
| Cost Structure | Higher initial investment in equipment and process development, but mass production can reduce unit labor costs and improve equipment utilization. | Lower initial equipment investment, but higher long-term labor, training, and management costs. |
| Resource Utilization | Stable control of toolpaths and material removal helps reduce over-processing and consumable waste. | Material and consumable usage is more easily affected by operating methods and operator differences. |
| Suitable Applications | Medium- to high-volume production, processes requiring high quality consistency and repeatability, or demanding working environments. | Prototyping, low-volume production, special workpieces, detailed finishing, and areas that are difficult to automate. |
Production volume, material, geometry, surface quality, and process requirements vary by product. Robotic and manual surface finishing each have their own advantages. DS evaluates product characteristics, cycle time, and quality requirements to determine the most suitable process configuration.
Best suited for medium- to high-volume production, repetitive processes, and applications requiring consistent quality. Standardized robot paths, compliant force control, tooling, and process parameters help stabilize cycle times and surface quality while reducing prolonged operator exposure to dust, noise, vibration, and physically demanding work.
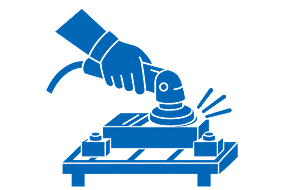
Best suited for prototyping, high-mix low-volume production, special workpieces, and detailed finishing. Operators can adjust the process in real time based on actual workpiece conditions, providing greater flexibility for tight corners, localized defects, complex details, and frequently changing products.
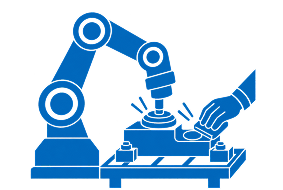
Ideal for processes that require a balance of production efficiency, quality consistency, and flexibility in detailed finishing. Robots handle the primary processing areas and repetitive operations, while operators perform work on tight corners, localized touch-up, and special areas, creating a complementary automated and manual finishing process.
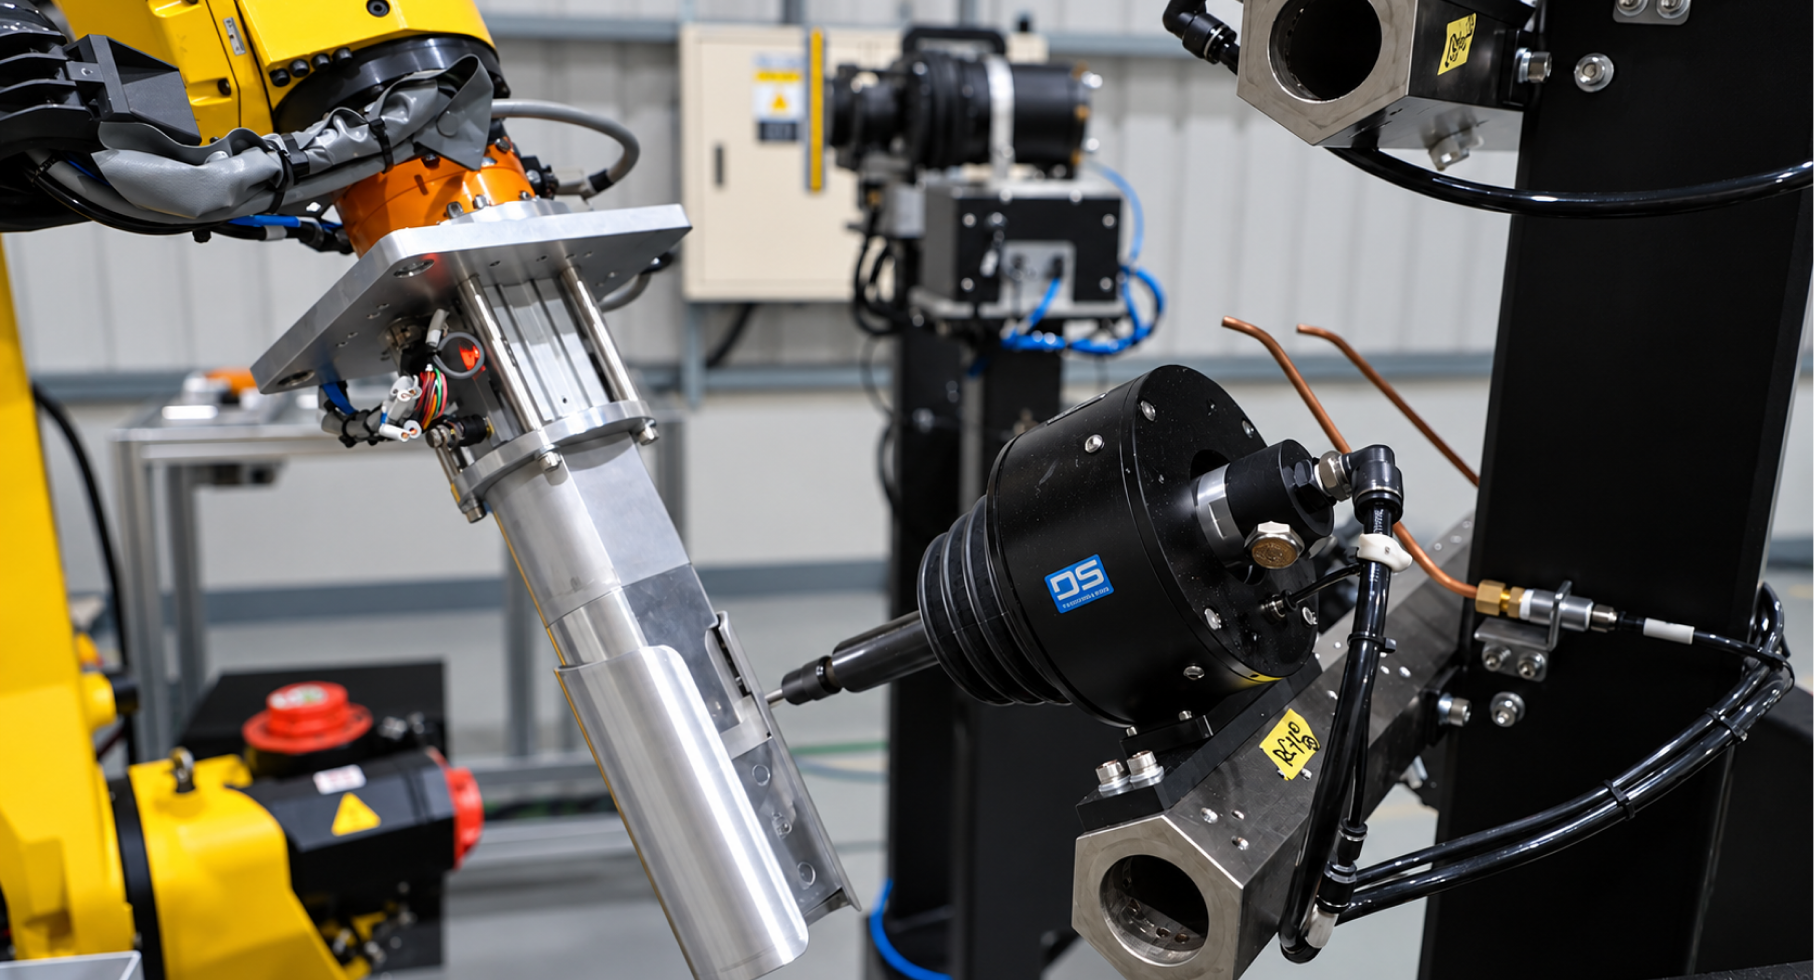
DS FlexRC™ SmartCell™ integrates active and passive compliant tools, pneumatic/electric spindles, belt grinding and polishing equipment, modular process tools, and automated consumable change technologies. It provides two standardized surface finishing architectures: Robot Holds Tool and Robot Holds Workpiece.
Each workstation can be flexibly configured with tools, consumables, tool-change modules, and peripheral equipment according to workpiece material, size, geometry, process requirements, and production capacity. Supported processes include deburring, grinding, weld finishing, polishing, and surface finishing.
In addition to standardized equipment, DS provides customized Turnkey solutions based on production capacity, cycle time, and process requirements, covering process development, tool selection, equipment configuration, and complete line delivery.
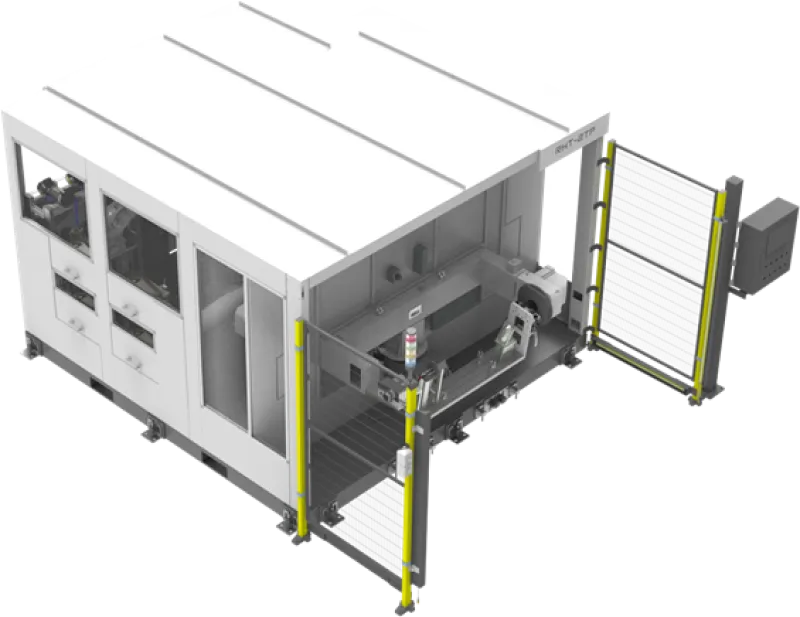
Robot-Holds-Tool Dual-Station Surface Finishing Workstation

Robot-held-tool processing with alternating dual-station operation improves equipment utilization.

Supports automatic tool change and automated sandpaper / abrasive belt replacement.

Suitable for medium to large workpieces, complex surfaces, weld finishing, deburring, grinding, and polishing.
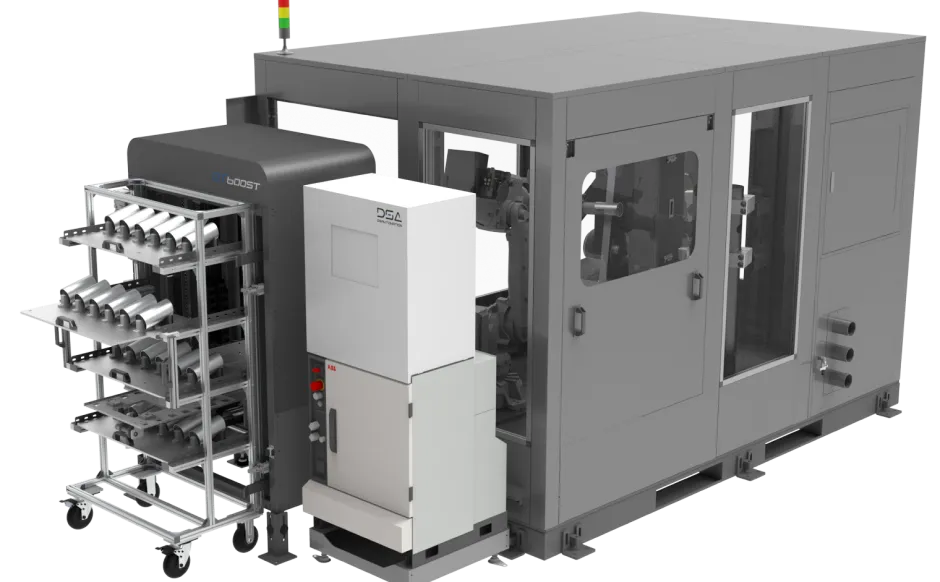
Robot-Holds-Workpiece Modular Surface Finishing Workstation

The robot holds the workpiece and automatically transfers it between processing stations to complete multiple surface finishing processes.

Stations can be configured as dedicated single-process stations or multifunction stations, supporting small to medium-sized workpieces, high-mix production, and complex-surface processing.

Grinding, deburring, flap-wheel, and polishing modules can be flexibly combined according to cycle-time and production-capacity requirements.
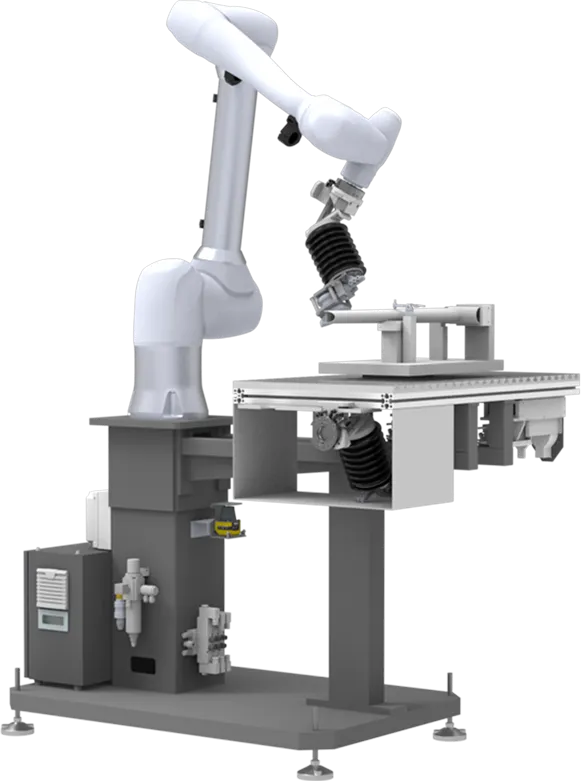
Collaborative Robot-Holds-Tool Surface Finishing Workstation

Collaborative Robot-Holds-Tool Surface Finishing Workstation

Suitable for medium to large workpieces, localized processing, prototyping, small-batch production, and high-mix manufacturing.

Supports automatic tool change and sandpaper / abrasive belt replacement for deburring, grinding, weld finishing, polishing, and surface finishing.
Automatic Sandpaper Change System for RTH / CRTH Series
Automatic Abrasive Belt Change System for RTH / CRTH Series
Automatic Sandpaper Change System for RWH Series
DS FlexRC™ provides a comprehensive platform of active and passive compliance tools, supporting radial, axial, angular, parallel-axis, and multi-directional compliant force control. The platform can be integrated with pneumatic and electric spindles, sandpaper, belt grinding equipment, flap wheels, polishing tools, and cutting tools to meet a wide range of surface finishing requirements.
Different compliance tools and process modules can be selected according to processing direction, contact force, tool load, workpiece geometry, and surface quality requirements. Automatic tool change and sandpaper / abrasive belt change systems can also be integrated to support deburring, grinding, weld finishing, polishing, and surface finishing, improving process stability, continuous production capability, and quality consistency.
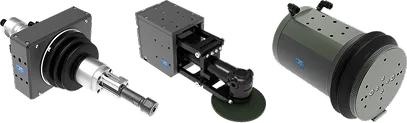
Robotic Compliance Tools for Surface Finishing
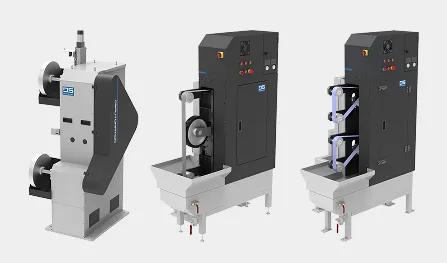
Robotic Compliant Belt Grinding Equipment

FlexRC™ provides compliant tools, belt grinding equipment, pneumatic/electric spindles, and automated consumable change modules that can be flexibly selected and integrated according to process requirements.

Based on workpiece material, size, process, and production capacity requirements, Robot-Holds-Tool or Robot-Holds-Workpiece SmartCell™ configurations can be selected to rapidly build application-specific surface finishing workstations.

From process testing and tool selection to robot path planning, automation integration, pilot production validation, and on-site implementation, DS provides complete Turnkey solutions ready for production.
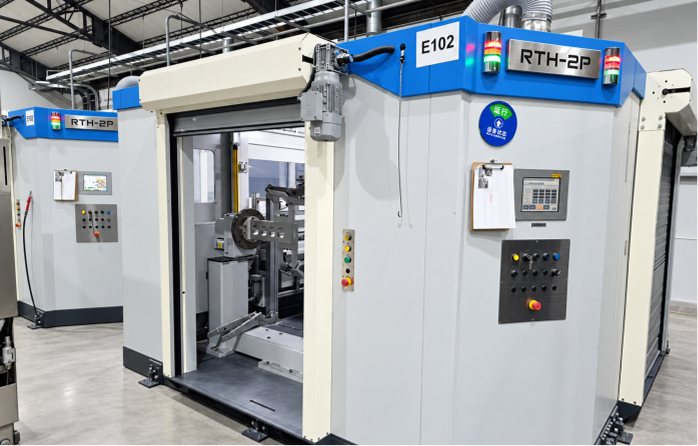
RTH-2TP uses a Robot-Holds-Tool processing architecture with a dual-station rotary positioning platform. While the robot performs surface finishing on one station, loading, unloading, and workpiece preparation can be carried out simultaneously on the other. Alternating operation between the two stations reduces idle time and improves equipment utilization and production efficiency.
The system features a standardized machine platform and modular process design. Depending on workpiece size, material properties, processing area, and surface quality requirements, it can be flexibly configured with FlexRC™ compliant tools, automatic tool change systems, ASC4-RTH automatic sandpaper change systems, ABSC4-RTH automatic abrasive belt change systems, pneumatic/electric spindles, and other process modules. Applications include deburring, weld finishing, grinding, polishing, cutting and trimming, and precision surface finishing.

Alternating Dual-Station Operation

Automatic Tool & Consumable Change

Complex-Surface Grinding & Polishing

Modular & Flexible Expansion

Pneumatic / Electric Spindle Options

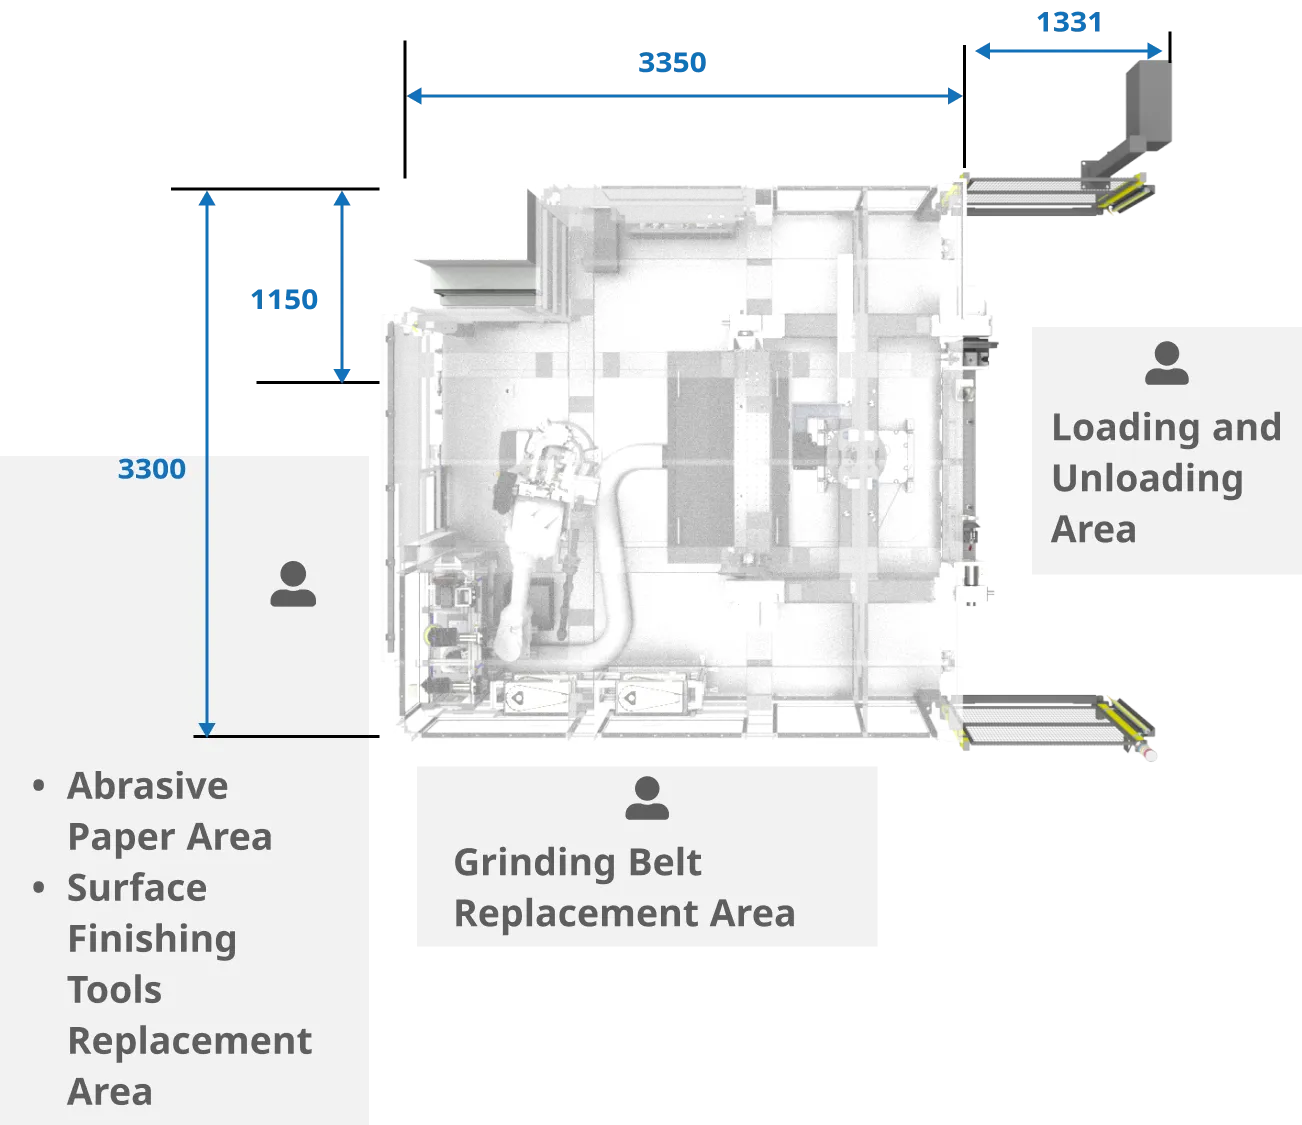
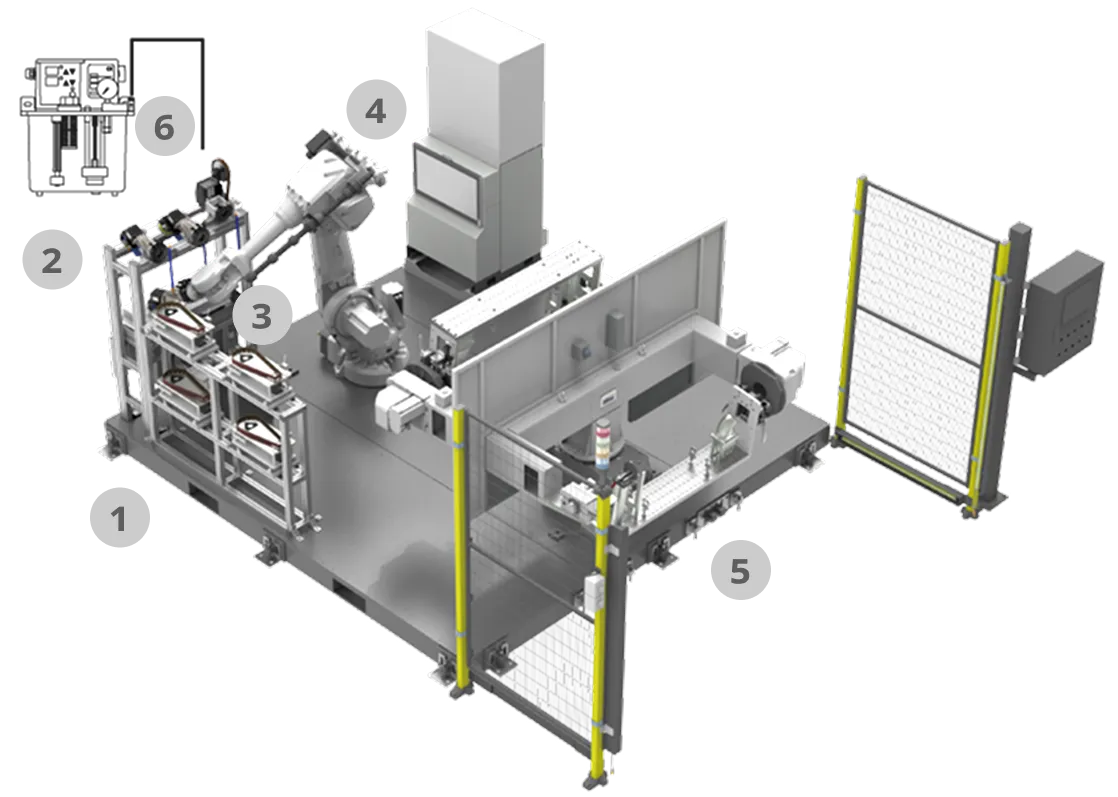
Supports RTH-2TP / RTH-2P Series surface finishing workstations and is compatible with LCZ / LRCZ compliant tools and BSA400 / BSA800 Series process tools. Multiple abrasive consumables can be configured according to process requirements. External supply and automatic change mechanisms enable automated sandpaper or abrasive belt replacement, reducing manual changeover and machine waiting time while improving continuous processing efficiency and equipment utilization.

Active / passive compliant force control, flexibly configured according to processing direction, contact force, and process requirements.

Enables rapid robot-side tool change to improve flexibility in multi-process applications.

Dust collection and treatment equipment can be configured according to abrasive dust, material characteristics, and processing environment requirements.

Supports automatic replenishment and replacement of abrasive consumables.

Different process tools can be configured according to speed, torque, and process requirements.

Supports path planning, program generation, and machine calibration.

Supports integration of equipment status, process information, and production data.

Deburring

Weld Finishing

Machining & Trimming

Polishing

Grinding

Cutting

Brushing

Surface Finishing
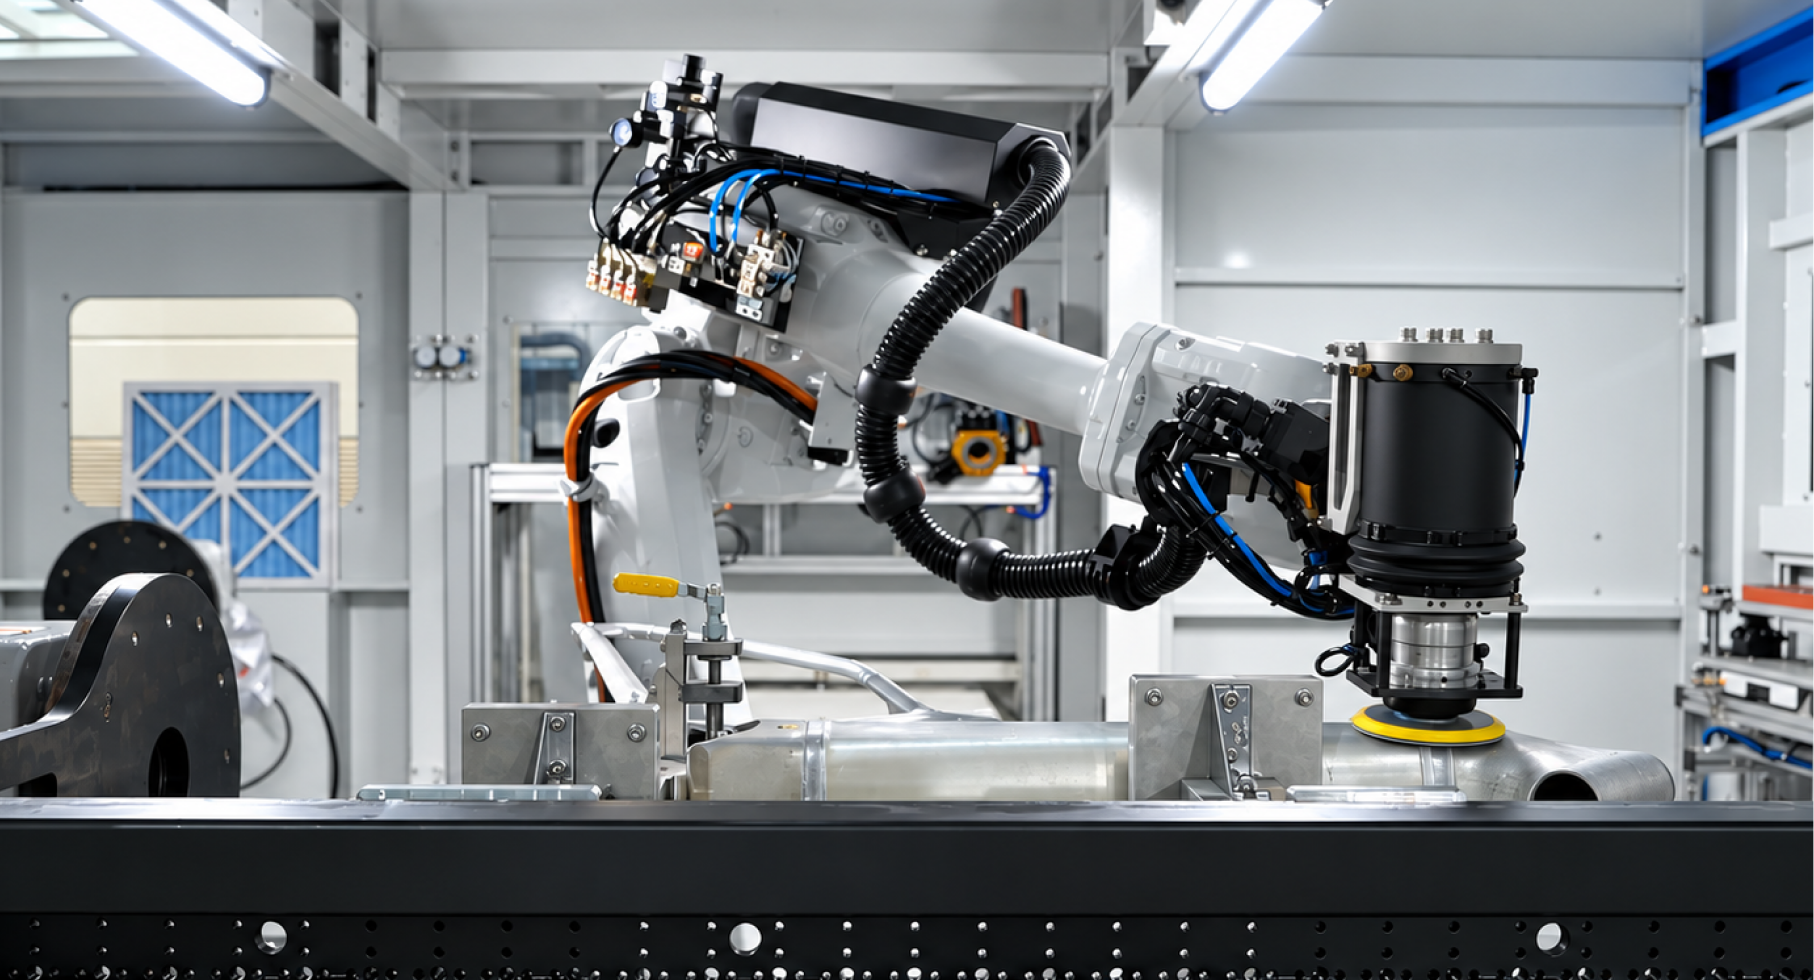
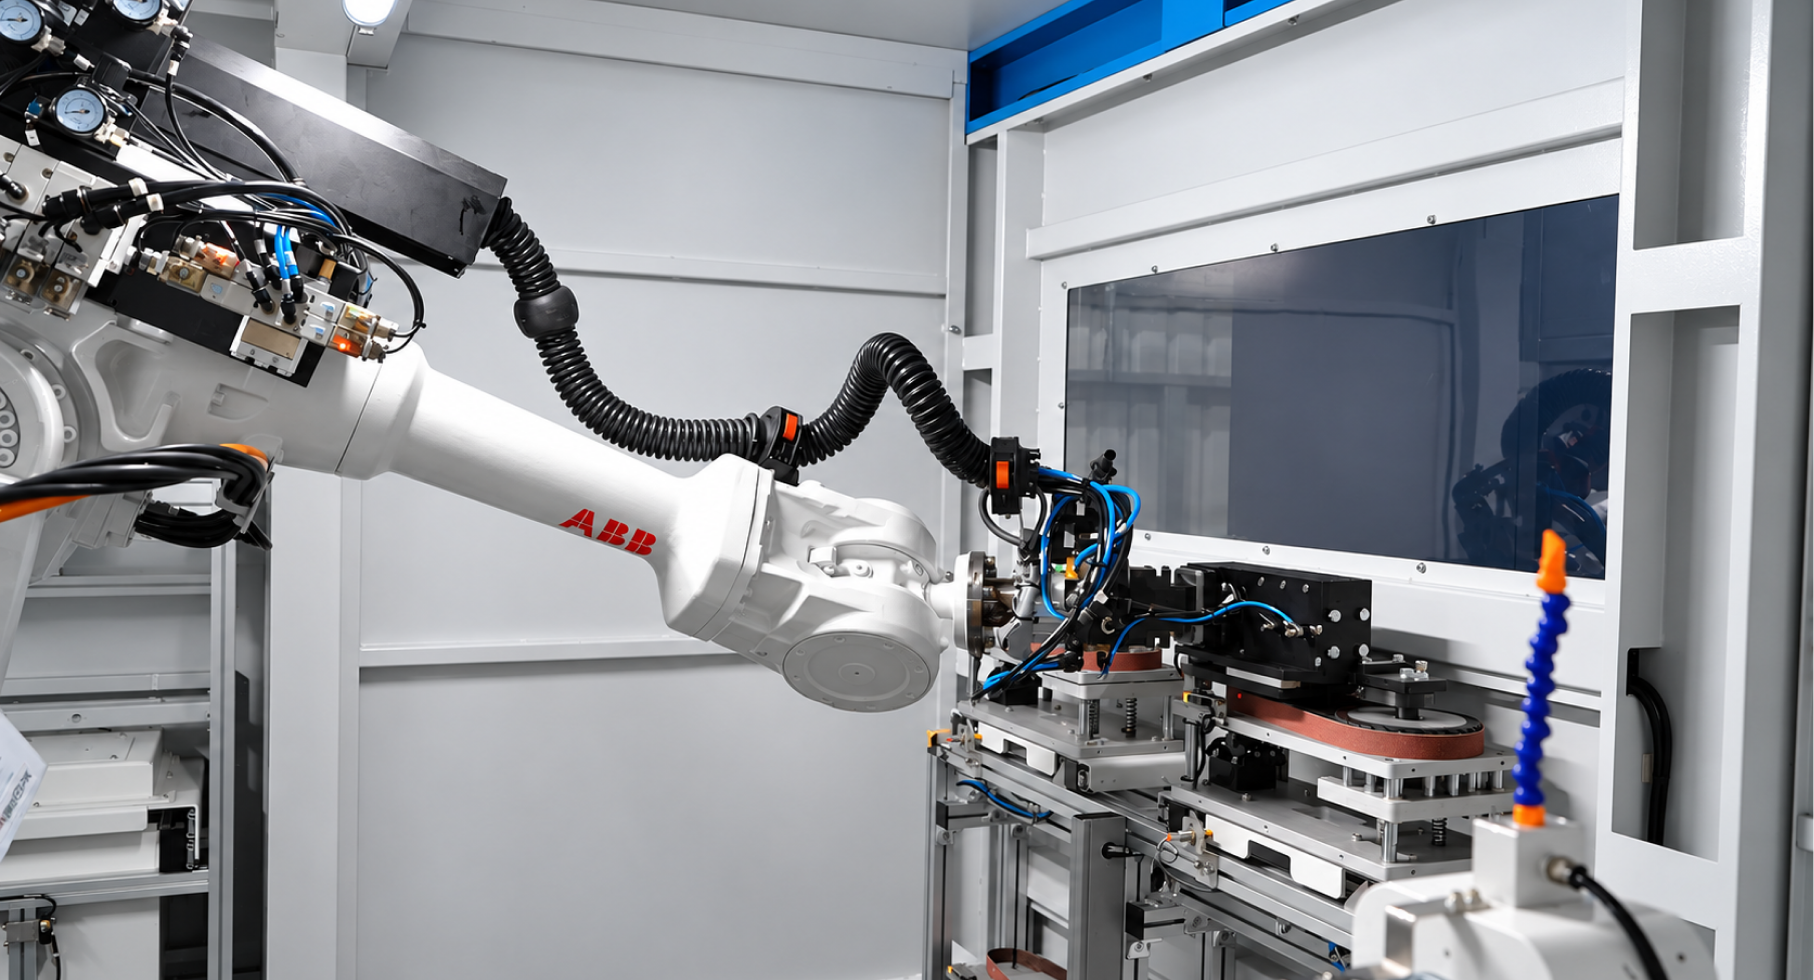
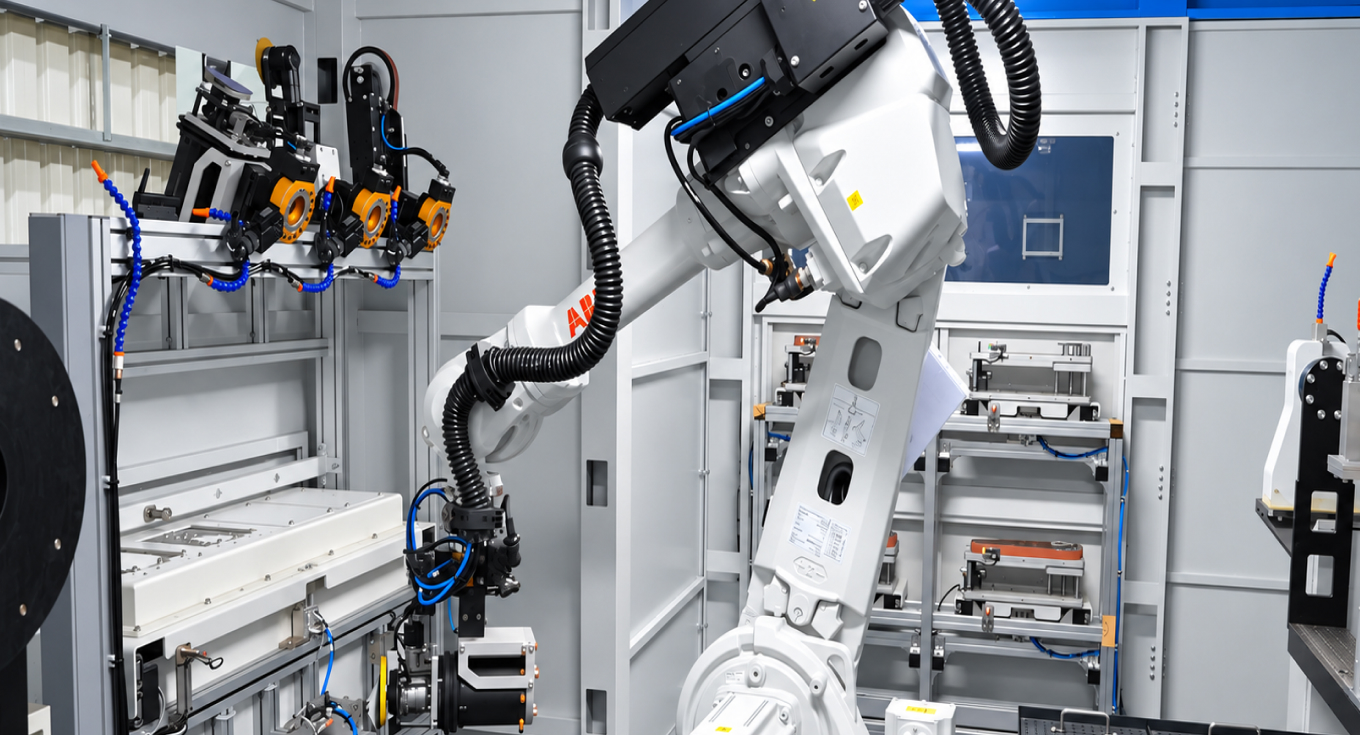
Grinding, finishing, and polishing are applied to stamped sheet-metal parts, weld seams, edges, and surfaces to improve appearance quality and prepare the workpiece for subsequent coating processes.
Suitable for removing parting lines, gates, risers, burrs, and rough surfaces from castings, as well as grinding and finishing prior to coating.
Deburring, chamfering, grinding, and polishing are applied to machined burrs, sharp edges, and localized surfaces to improve product consistency and surface quality.
Grinding, brushing, and surface finishing are applied to formed parts and complex surfaces to support subsequent welding, coating, and assembly processes.
Suitable for machining, trimming, grinding, and finishing of flash, burrs, and rough surface areas after forging.
Supports machining, trimming, grinding, and surface finishing of carbon fiber, glass fiber, and other composite materials, helping reduce variation in manual processing.
Alternating dual-station operation reduces machine waiting time and the impact of manual loading and unloading.
Compliant force control, toolpath management, and process parameters improve processing consistency.
Reduces operator exposure to grinding operations, dust, noise, and highly repetitive tasks.
Supports integration of automatic tool change, sandpaper / abrasive belt replacement, and peripheral equipment.
Smart manufacturing and digital functions can be optionally integrated according to equipment management, process data, and robot programming requirements.
Supports equipment status monitoring, process information, and production data management to improve equipment and process visibility.
Integrates equipment manuals, technical documentation, and maintenance information to provide operational support, troubleshooting, and maintenance guidance.
Supports robot path planning, offline programming, and machine calibration, reducing on-site programming time and improving changeover efficiency.
Safety protection, dust collection and treatment, and related peripheral systems are configured according to equipment risks and process requirements to improve the surface finishing work environment.
Tool selection and system configuration are tailored to workpiece size, material properties, processing area, surface quality, cycle time, and production capacity requirements.
Provides equipment maintenance, process adjustment, technical support, and future system expansion services.
Equipment can be designed and configured according to project and target-market requirements, with support for applicable CE, UL, JIS, and other relevant safety and electrical requirements.
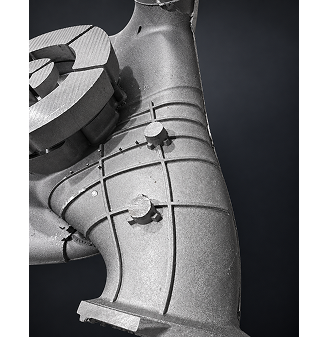
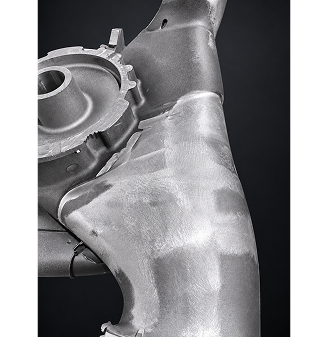
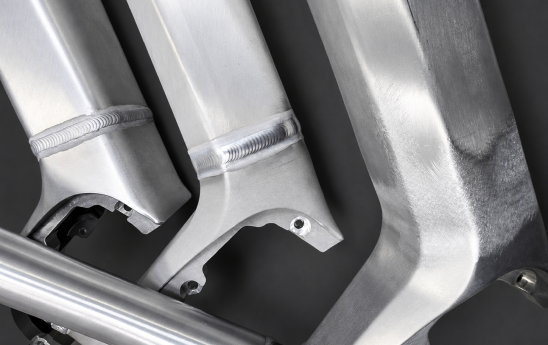
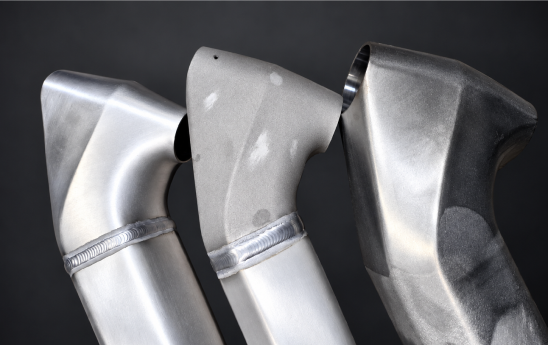
DS not only provides robotic surface finishing equipment, but also validates processing results through actual process testing and measurement. For grinding, weld finishing, polishing, and surface finishing, surface roughness, appearance quality, and process consistency can be verified according to product requirements, establishing measurable process parameters and quality validation criteria.
Before & After Grinding
Welding & Weld Bead Finishing
Process Illustration
Workpieces in the photos are arranged in process order
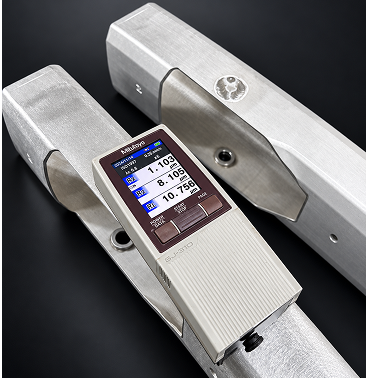
After weld grinding and surface finishing, surface roughness measurement can be used to verify processing results and surface quality consistency.
In the example shown, the measured surface roughness was Ra 1.3 μm. Process parameters can then be adjusted according to subsequent coating, appearance, and product functional requirements.
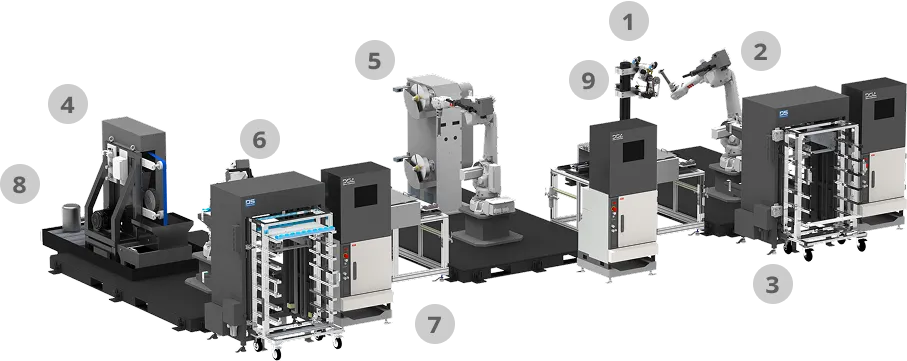
RWH-3DF features a Robot-Holds-Workpiece architecture with modular multi-station processing. The robot transfers the workpiece between different process stations in sequence to perform rough grinding, fine grinding, deburring, flap-wheel finishing, polishing, and final surface finishing.
Each station can be flexibly configured according to actual production requirements. For high-volume and fixed-process applications, dedicated single-process stations can keep each tool or belt grinding unit under optimized, fixed processing conditions, reducing tool-change and setup time while increasing throughput. For high-mix, low-volume production, space-constrained layouts, or multi-process requirements, multiple functions can also be integrated into a single station to improve system flexibility.
By flexibly combining dedicated and multifunction stations, RWH-3DF can be configured according to workpiece characteristics, cycle time, production capacity, investment requirements, and surface quality targets. Process modules can also be added or adjusted as production needs change, balancing productivity, equipment investment, and process flexibility.

Flexible Multi-Station Configuration

Dedicated Stations for Higher Efficiency

Multifunction Station Integration

Automatic Robotic Process Transfer

Automatic Consumable Change
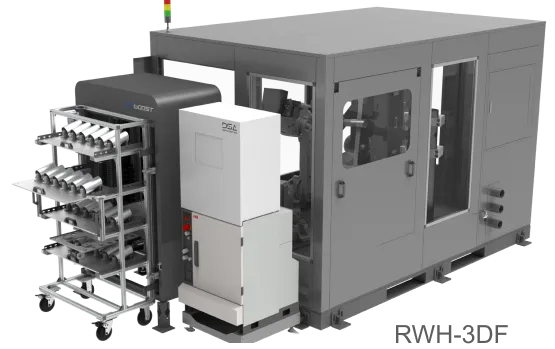
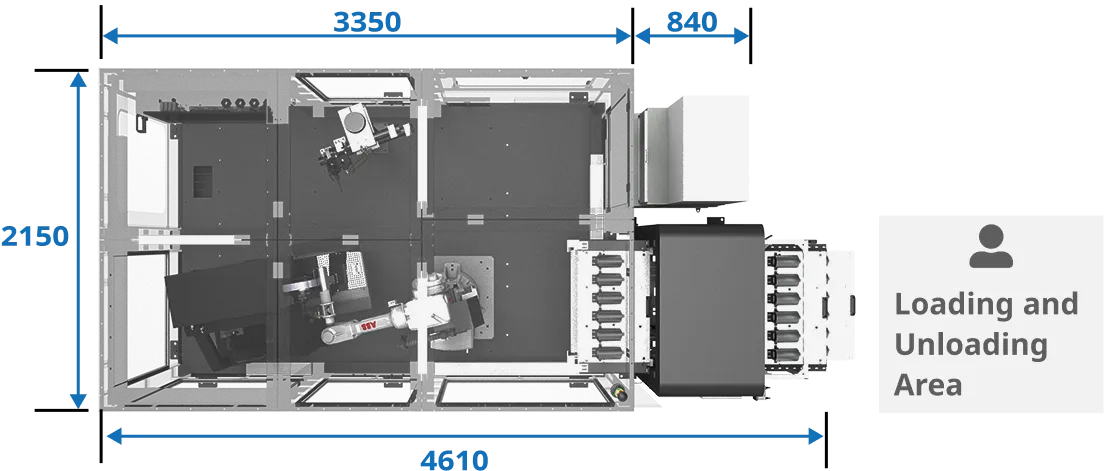
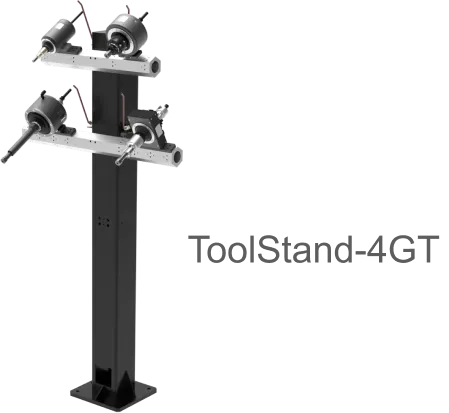

RWH-3DF allows different processing modules to be flexibly combined according to product processes, cycle time, and production capacity requirements. Each station can be dedicated to a single process to maximize tool and equipment utilization, or multiple processing functions can be integrated into one station to support high-mix production and process flexibility.
The system can integrate FlexRC™ compliant tools, FlexRC™ EBS Series belt grinding equipment, flap-wheel / polishing modules, the ASC4-RWH automatic sandpaper change system, ToolStand-4GT tool racks, workpiece flipping modules, and AFS-3D multi-layer automated feeding equipment. The robot holds the workpiece and automatically transfers it between stations to create a complete multi-process surface finishing system.
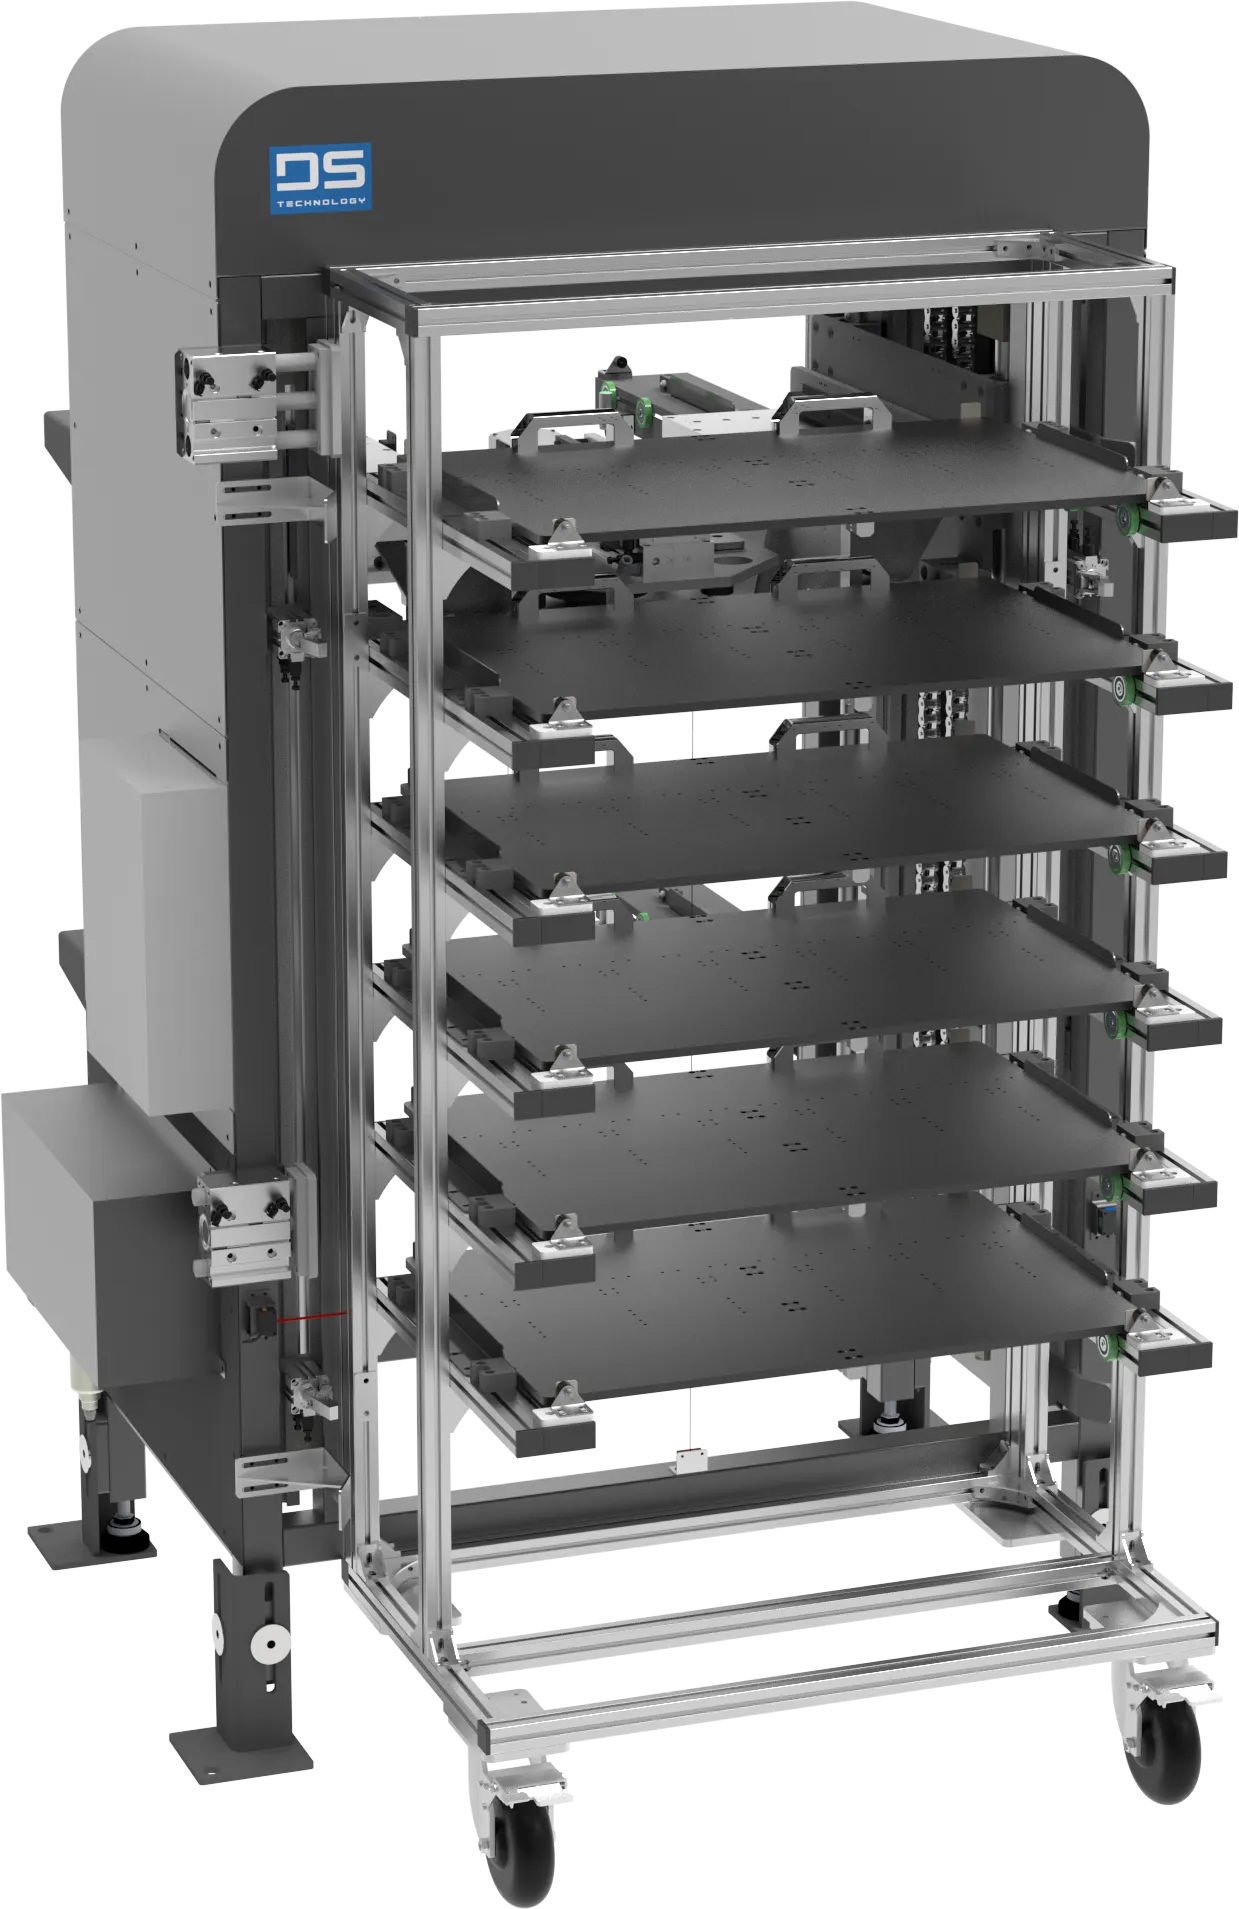
Multi-layer racks can be configured according to workpiece size, maximizing vertical space utilization while reducing system footprint and increasing workpiece storage capacity.
A mobile cart design enables complete workpiece carts to be replenished or exchanged directly, reducing manual replenishment time and improving continuous production efficiency.
Workpieces can be automatically picked and placed by the robot, with optional AMR replenishment and smart logistics integration according to production-line requirements.
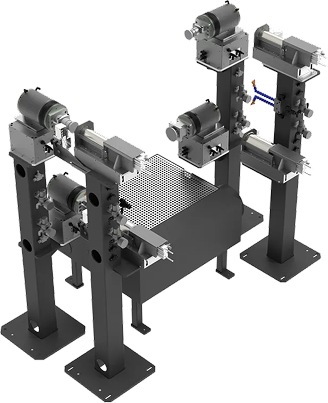
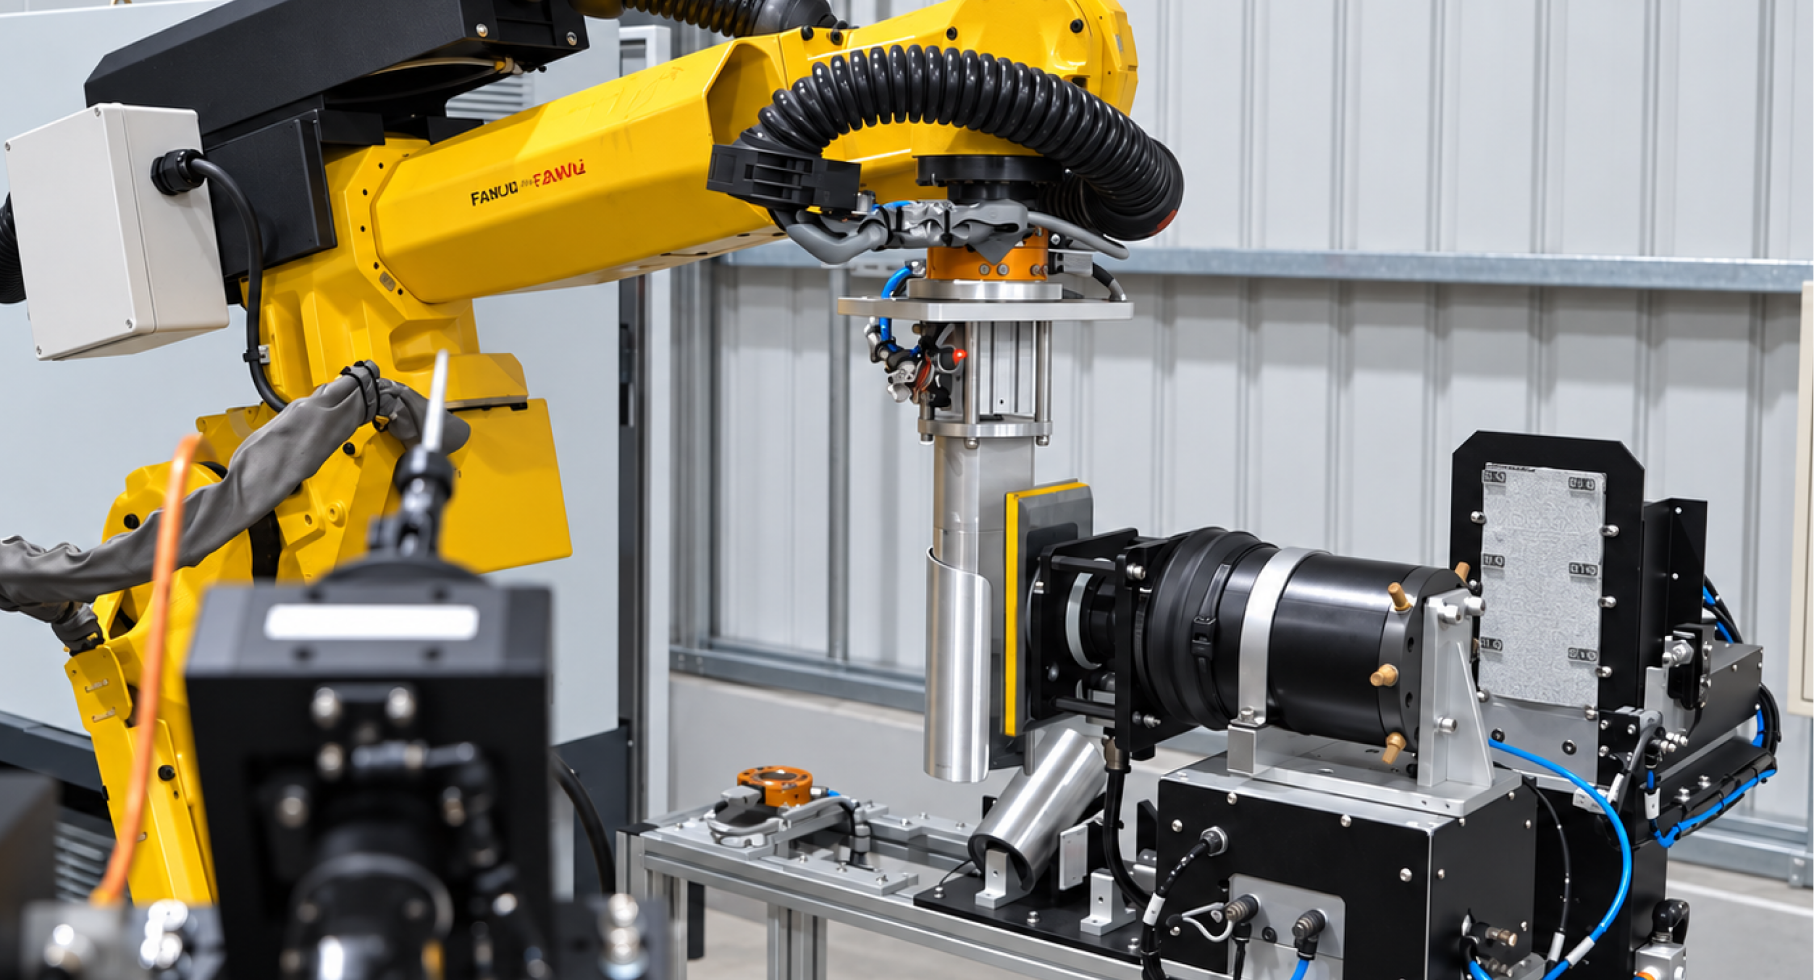
ASC4-RWH is specifically designed for RWH Series Robot-Holds-Workpiece surface finishing systems. It can be integrated with random orbital or rotary sanders and FlexRC™ compliant tools, allowing different sandpaper sizes and grit grades to be configured according to process requirements, with automatic sandpaper selection and replacement.
Compliant force control and sanding processes maintain stable contact force between the workpiece and sandpaper, improving grinding consistency and surface quality. The system can also perform precision grinding and surface finishing on localized areas, small surfaces, and complex locations according to workpiece geometry and process requirements.
Automatic sandpaper consumable replacement reduces manual intervention and consumable changeover time, supporting multiple grit grades, multi-process applications, and continuous automated processing.

Supports multi-layer storage, full-cart rapid replenishment, and automatic robotic pick-and-place, with optional AMR logistics integration.

Dry, wet, or other suitable dust management solutions can be configured according to processed material, dust characteristics, and safety requirements.

Integrated compliant force control enables flexible configuration for rough grinding, fine grinding, weld finishing, and surface finishing.

Supports multi-side processing and automatic transfer between stations, expanding the accessible processing range of the workpiece.

Integrated with random orbital or rotary sanders and FlexRC™ compliant tools, the system automatically switches between different sandpaper grit grades and supports localized, small-area, and precision surface grinding.

Different FlexRC™ compliant tools and process tools can be configured to support flexible multi-process changeover.

Supports integration of equipment status, process information, and production data.
Depending on cycle time and production capacity requirements, processes can be configured using dedicated single-process stations or multifunction stations, with the robot automatically transferring the workpiece between stations.
Deburring
Drilling / Machining
Polishing
Rough & Fine Grinding
Cutting & Trimming
Surface Finishing
Grinding, finishing, and polishing are applied to stamped sheet-metal parts, weld seams, edges, and surfaces to improve appearance quality and prepare the workpiece for subsequent coating processes.
Suitable for removing parting lines, gates, risers, burrs, and rough surfaces from castings, as well as grinding and finishing prior to coating.
Deburring, chamfering, grinding, and polishing are applied to machined burrs, sharp edges, and localized surfaces to improve product consistency and surface quality.
Grinding, brushing, and surface finishing are applied to formed parts and complex surfaces to support subsequent welding, coating, and assembly processes.
Suitable for machining, trimming, grinding, and finishing of flash, burrs, and rough surface areas after forging.
Supports machining, trimming, grinding, and surface finishing of carbon fiber, glass fiber, and other composite materials, helping reduce variation in manual processing.
Dedicated single-process or multifunction stations can be combined according to process requirements, cycle time, investment, and production capacity.
Dedicated stations maintain fixed tools, consumables, and process parameters, reducing tool changes and setup time.
The robot holds the workpiece and automatically transfers it between stations, enabling continuous rough grinding, fine grinding, deburring, polishing, and surface finishing.
Compliant force control, automated feeding, and consumable management improve process consistency while reducing labor requirements for highly repetitive operations.
Smart manufacturing and digital functions can be optionally integrated according to equipment management, process data, and robot programming requirements.
Supports equipment status monitoring, process information, and production data management to improve equipment and process visibility.
Integrates equipment manuals, technical documentation, and maintenance information to provide operational support, troubleshooting, and maintenance guidance.
Supports robot path planning, offline programming, and machine calibration, reducing on-site programming time and improving changeover efficiency.
Safety protection, dust collection and treatment, and related peripheral systems are configured according to equipment risks and process requirements to improve the surface finishing work environment.
Tool selection and system configuration are tailored to workpiece size, material properties, processing area, surface quality, cycle time, and production capacity requirements.
Provides equipment maintenance, process adjustment, technical support, and future system expansion services.
Equipment can be designed and configured according to project and target-market requirements, with support for applicable CE, UL, JIS, and other relevant safety and electrical requirements.
DS not only provides robotic surface finishing equipment, but also validates processing results through actual process testing and measurement. For grinding, weld finishing, polishing, and surface finishing, surface roughness, appearance quality, and process consistency can be verified according to product requirements, establishing measurable process parameters and quality validation criteria.
Before & After Grinding
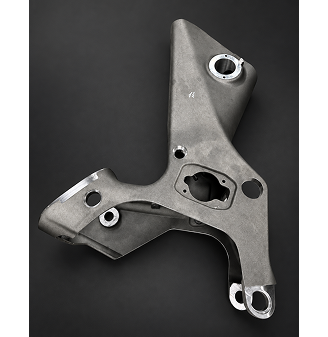
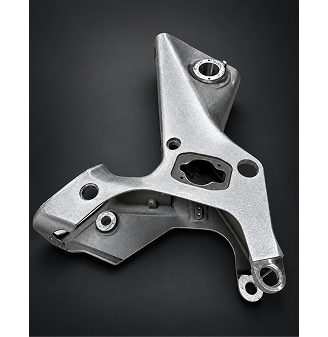
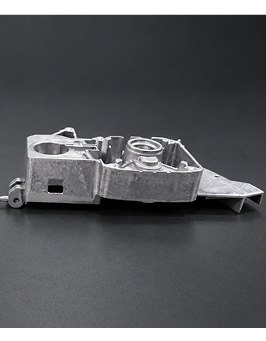
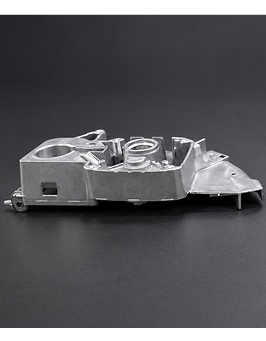
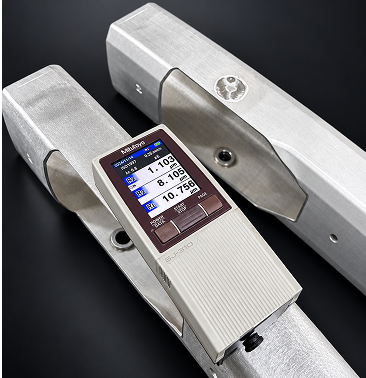
After weld grinding and surface finishing, surface roughness measurement can be used to verify processing results and surface quality consistency.
In the example shown, the measured surface roughness was Ra 1.3 μm. Process parameters can then be adjusted according to subsequent coating, appearance, and product functional requirements.
CRTH-1P features a collaborative Robot-Holds-Tool architecture integrating FlexRC™ compliant tools, automatic tool change, and automated consumable change modules to provide a highly flexible robotic surface finishing solution.
The system can be flexibly integrated into existing manual work areas, supporting human-robot collaboration, localized processing, and high-mix production. Because the robot holds the processing tool rather than the workpiece, it is particularly suitable for medium to large workpieces, complex areas, and targeted processing locations. Supported processes include deburring, grinding, weld finishing, polishing, and surface finishing.
CRTH-1P can also integrate automatic tool change, sandpaper / abrasive belt consumable change, pneumatic / electric spindles, and different FlexRC™ compliant tools, supporting prototyping, small-batch production, high-mix manufacturing, and changing process requirements.
Human-Robot Collaboration

Medium-to-Large Workpiece Processing
Flexible Deployment

Automatic Tool & Consumable Change

Multi-Process Surface Finishing
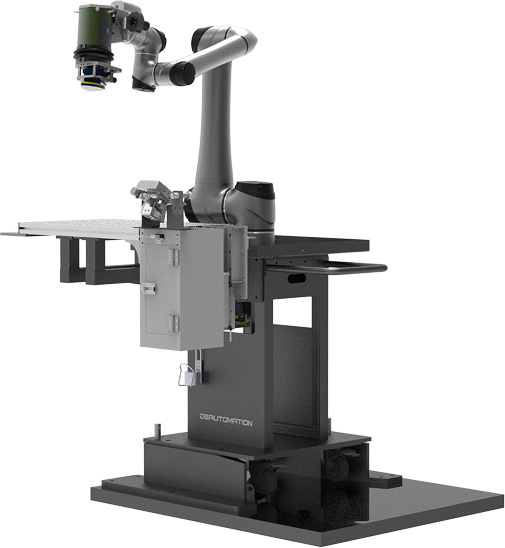
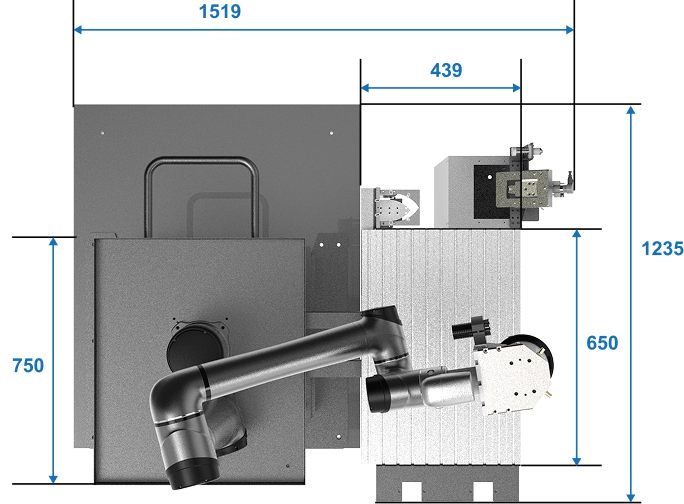
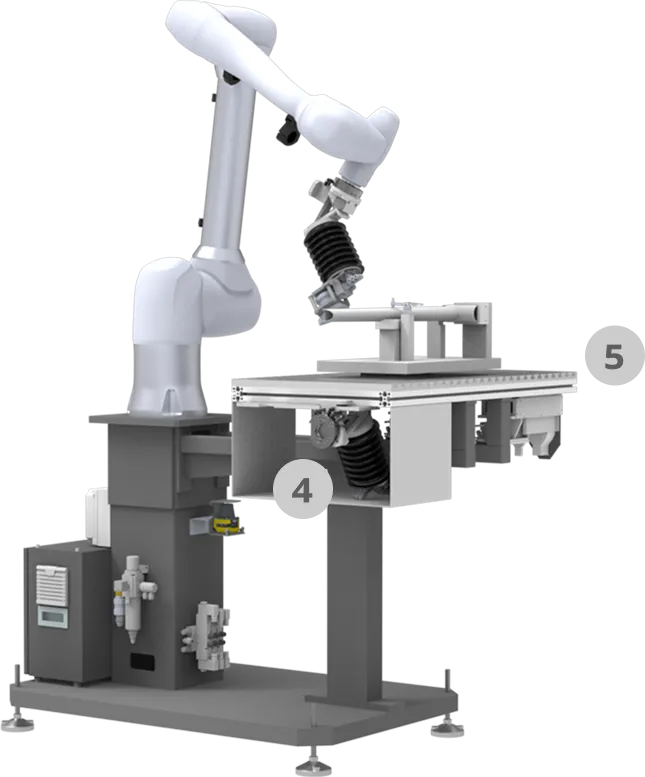
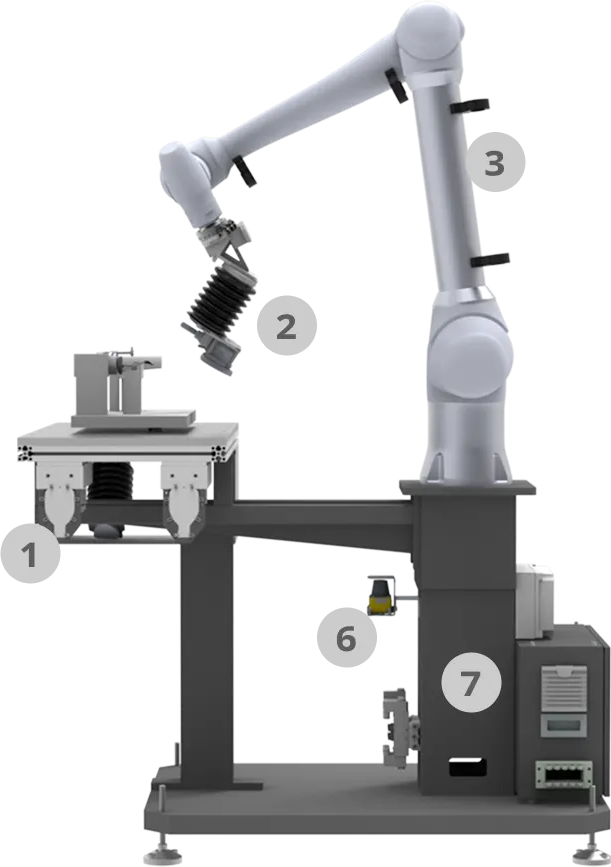
Standard and optional modules can be flexibly configured according to customer process and application requirements.
Grinding, finishing, and polishing are applied to stamped sheet-metal parts, weld seams, edges, and surfaces to improve appearance quality and prepare the workpiece for subsequent coating processes.
Suitable for removing parting lines, gates, risers, burrs, and rough surfaces from castings, as well as grinding and finishing prior to coating.
Deburring, chamfering, grinding, and polishing are applied to machined burrs, sharp edges, and localized surfaces to improve product consistency and surface quality.
Grinding, brushing, and surface finishing are applied to formed parts and complex surfaces to support subsequent welding, coating, and assembly processes.
Suitable for machining, trimming, grinding, and finishing of flash, burrs, and rough surface areas after forging.
Supports machining, trimming, grinding, and surface finishing of carbon fiber, glass fiber, and other composite materials, helping reduce variation in manual processing.
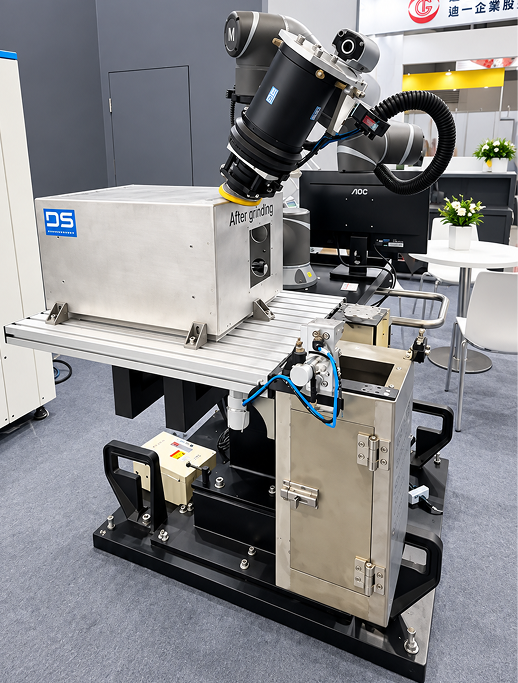
Can be configured around existing work areas and production processes, supporting collaborative operation between manual tasks and robotic automated processing.
The Robot-Holds-Tool architecture eliminates the requirement for the robot to grip the workpiece, making it suitable for medium to large workpieces and targeted processing areas.
Reduces operator exposure and physical workload associated with grinding, dust, noise, and highly repetitive operations.
FlexRC™ compliant tools, automatic tool change, sandpaper / abrasive belt consumable change, and pneumatic / electric spindles can be integrated according to application requirements.
Smart manufacturing and digital functions can be optionally integrated according to equipment management, process data, and robot programming requirements.
Supports equipment status monitoring, process information, and production data management to improve equipment and process visibility.
Integrates equipment manuals, technical documentation, and maintenance information to provide operational support, troubleshooting, and maintenance guidance.
Supports robot path planning, offline programming, and machine calibration, reducing on-site programming time and improving changeover efficiency.
Safety protection, dust collection and treatment, and related peripheral systems are configured according to equipment risks and process requirements to improve the surface finishing work environment.
Tool selection and system configuration are tailored to workpiece size, material properties, processing area, surface quality, cycle time, and production capacity requirements.
Provides equipment maintenance, process adjustment, technical support, and future system expansion services.
Equipment can be designed and configured according to project and target-market requirements, with support for applicable CE, UL, JIS, and other relevant safety and electrical requirements.
DS not only provides robotic surface finishing equipment, but also validates processing results through actual process testing and measurement. For grinding, weld finishing, polishing, and surface finishing, surface roughness, appearance quality, and process consistency can be verified according to product requirements, establishing measurable process parameters and quality validation criteria.
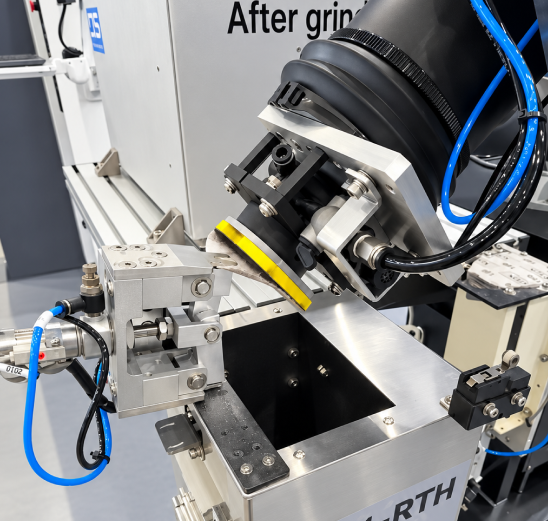
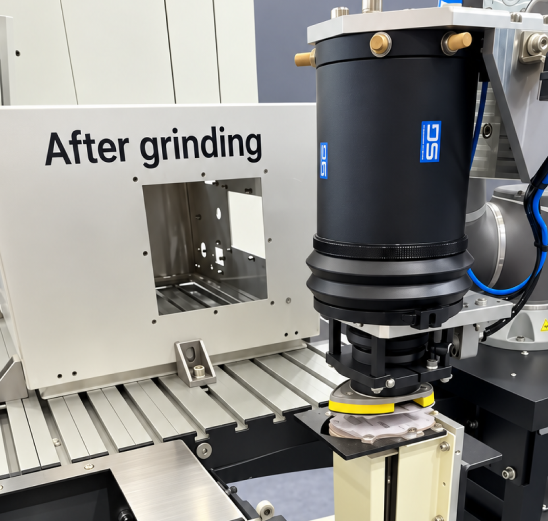
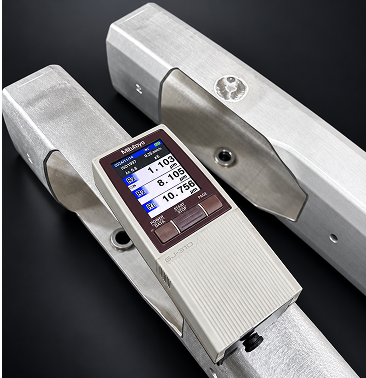
After weld grinding and surface finishing, surface roughness measurement can be used to verify processing results and surface quality consistency.
In the example shown, the measured surface roughness was Ra 1.3 μm. Process parameters can then be adjusted according to subsequent coating, appearance, and product functional requirements.
Tailored Turnkey surface finishing solutions based on workpiece, process, cycle time, and quality requirements.
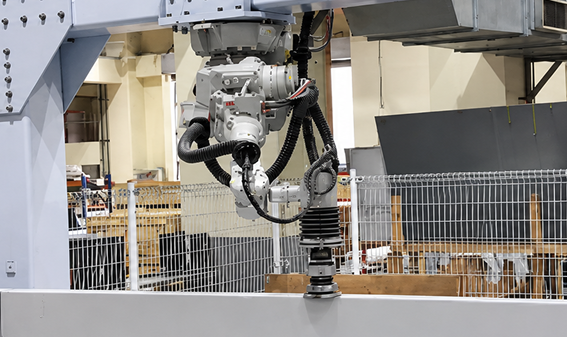
For surface finishing of large aluminum-alloy and stainless-steel structures, frames, and peripheral components commonly used in semiconductor equipment, RSFinC can be configured with large industrial robots, external axes, and dedicated process modules according to workpiece size, material characteristics, processing area, and surface quality requirements.
The system can integrate FlexRC™ compliant tools, grinding / polishing equipment, and automated consumable change modules to support grinding, polishing, weld finishing, and surface finishing. Process parameter management and robot path control improve processing consistency and production stability for large workpieces.
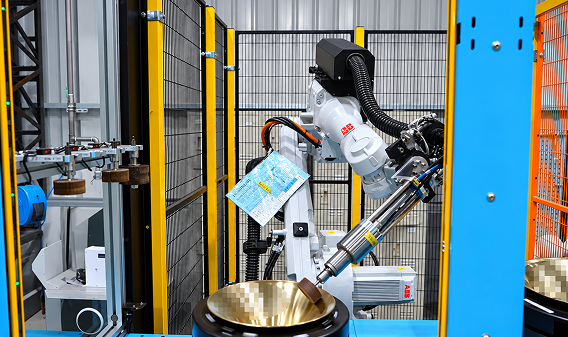
Saxophones, trumpets, and other brass instrument components feature extensive curved surfaces, welded joints, and demanding cosmetic requirements. Their finishing processes typically involve grinding, polishing, and detailed finishing, with high requirements for gloss consistency, surface texture, and localized finish quality.
By combining robotics with FlexRC™ compliant tools, polishing wheels, and dedicated grinding tools, contact force and processing paths can be controlled according to workpiece curvature and processing area. Automated grinding, polishing, and surface finishing improve cosmetic consistency while reducing process variation caused by differences in operator skill.
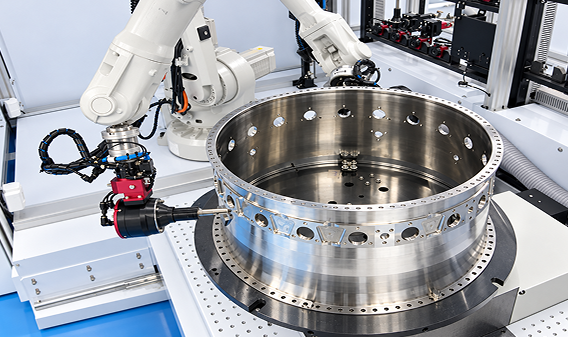
Inconel aerospace components often require additional deburring and surface finishing around hole edges, part edges, intersecting holes, and localized areas after CNC machining. Due to Inconel’s high strength, high-temperature resistance, corrosion resistance, and difficult machinability, tool selection, contact force control, and process consistency are particularly important.
RSFinC integrates robotics, FlexRC™ compliant tools, and dedicated deburring tools to automate deburring and localized surface finishing according to workpiece geometry and processing location. This reduces variation in manual operations and improves process consistency and stability in mass production of complex components.
Gold, silver, and other precious-metal alloy components require high levels of surface gloss, fine-detail definition, and cosmetic consistency. Due to the high value of the materials, the process must also carefully control material removal while maintaining surface quality.
By combining robotics with FlexRC™ compliant tools, polishing wheels, and precision grinding tools, contact force, toolpath, and processing conditions can be controlled according to workpiece geometry and specific processing areas. Automated fine grinding, polishing, and surface finishing improve gloss consistency and cosmetic quality while reducing over-polishing and variation in manual operations.
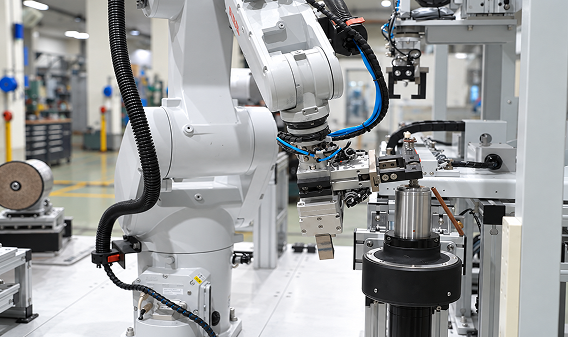
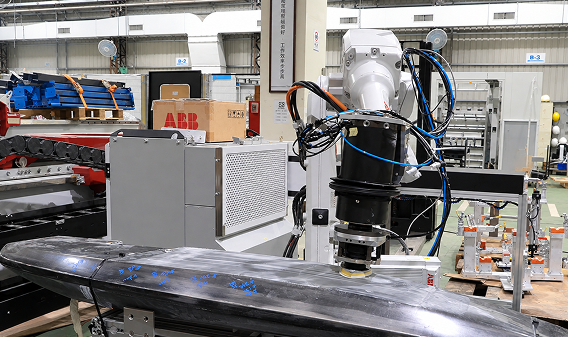
Carbon-fiber and glass-fiber composites are widely used in sporting goods, bicycles, surfboards, UAVs, and aerospace components. These products often feature large curved surfaces, complex contours, and demanding cosmetic requirements, requiring surface grinding, joint-area finishing, localized filler sanding, and final finishing before coating.
By combining robotics with FlexRC™ compliant tools and dedicated grinding equipment, contact force and toolpaths can be controlled according to changing workpiece curvature. This helps reduce over-grinding, localized unevenness, and manual variation while improving consistency and surface quality on complex curved surfaces and supporting automated processing of medium to large composite components.
Sand-cast iron components typically require additional post-processing such as flash removal, deburring, grinding, drilling, and localized machining. Variations in casting surfaces and geometry can also increase the workload and quality variation associated with manual finishing.
Based on casting size, gate and riser locations, burr distribution, and processing requirements, RSFinC can integrate robots, FlexRC™ compliant tools, grinding and cutting tools, drilling modules, workpiece positioning fixtures, and automatic transfer equipment to combine multiple casting post-processing operations into a continuous automated line.
Dedicated stations can separately perform deburring, edge grinding, grinding, and drilling, reducing physically demanding manual operations while improving cycle time, process consistency, and mass-production stability.
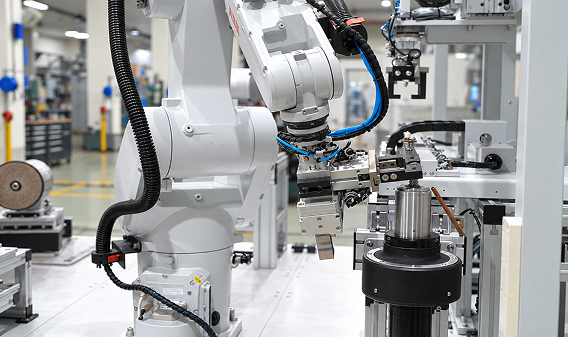
Robotic surface finishing not only improves production efficiency and processing consistency, but also reduces prolonged operator exposure to dust, noise, vibration, and highly repetitive work environments.
Stable control of processing paths, contact force, and process parameters helps reduce over-processing and unnecessary consumable usage. According to material, dust characteristics, and process requirements, dust collection, dust treatment, safety protection, and related peripheral systems can also be integrated to improve the working environment and process stability.
DS Technology combines FlexRC™ compliant force control, standardized SmartCell™, automatic tool change and consumable management, Robotmaster® offline programming and machine calibration, and customized Turnkey system integration to transform labor-intensive processes such as deburring, grinding, weld finishing, polishing, and surface finishing into stable, repeatable, and scalable automated solutions.
From individual process tools and standardized workstations to multi-station process integration and large customized production lines, DS develops suitable system architectures and processing solutions according to workpiece size, material properties, geometry, cycle time, production capacity, and surface quality requirements.
Compliant force control, robot path management, and process parameter control improve consistency and repeatability in surface finishing.
Supports integration of tool change, sandpaper / abrasive belt replacement, automated feeding, workpiece transfer, and multi-station processing.
From standardized RTH, RWH, and CRTH SmartCell™ platforms to customized RSFinC Turnkey systems, configurations can be tailored to process and production capacity requirements.
Covers process testing, tool selection, offline programming, TCP calibration, equipment integration, quality validation, and production implementation.
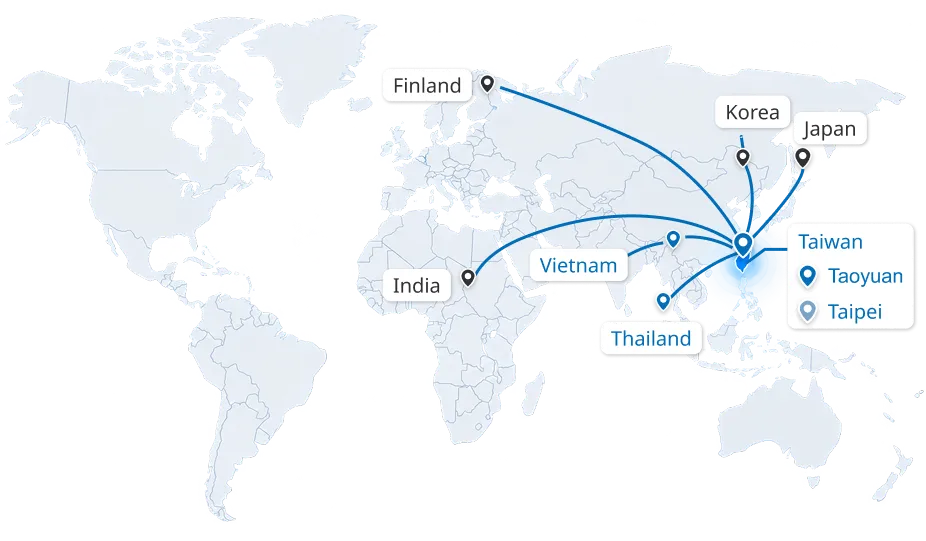
DS has established a diverse service and partner network across Asia and Europe and continues to expand its local support capabilities worldwide. We are currently developing our presence in North America and engaging with prospective distribution and technical service partners in the United States and Mexico to strengthen regional sales, technical support, and after-sales service capabilities.
Depending on market requirements, support is provided through DS technical teams, authorized partners, and ODM partners, strengthening equipment deployment, after-sales service, and long-term operational support.
Service Capabilities:
Installation & Commissioning
Technical Support
Maintenance
Spare Parts Support
Technical Training
System Upgrades
 DS Service Location
 Authorized Partner
 ODM Partner
Engineered in Taiwan. Supporting Manufacturing Worldwide.